演示目录 / build
2WD 探索机器人
一台会避障的两轮差速驱动机器人:经典的第一个项目,完全依据机器可读的零件记录选型。
智能体可读: markdown · 机器数据流: feed.json
Assembly diagram
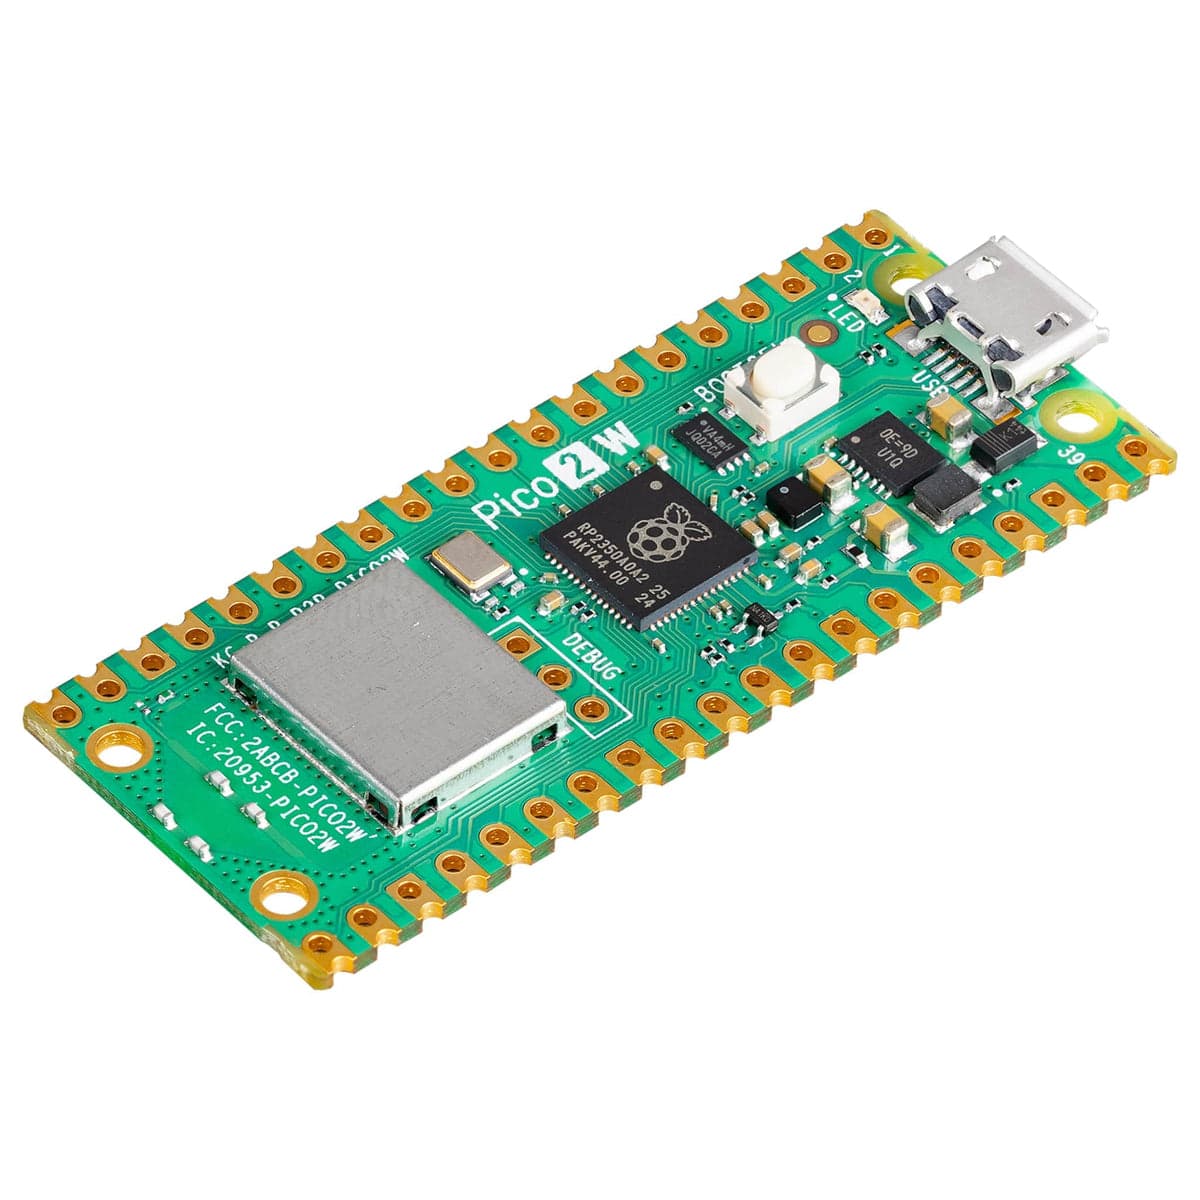 ControllerRaspberry Pi Pico 2 W
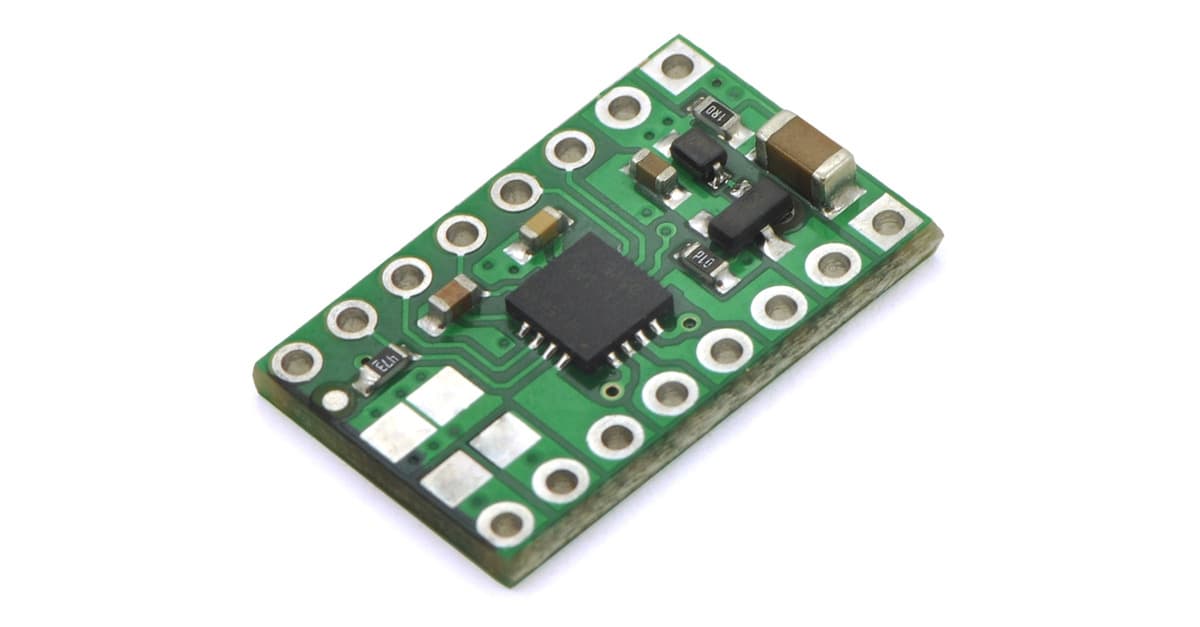 Motor driverDRV8833 dual motor driver carrier
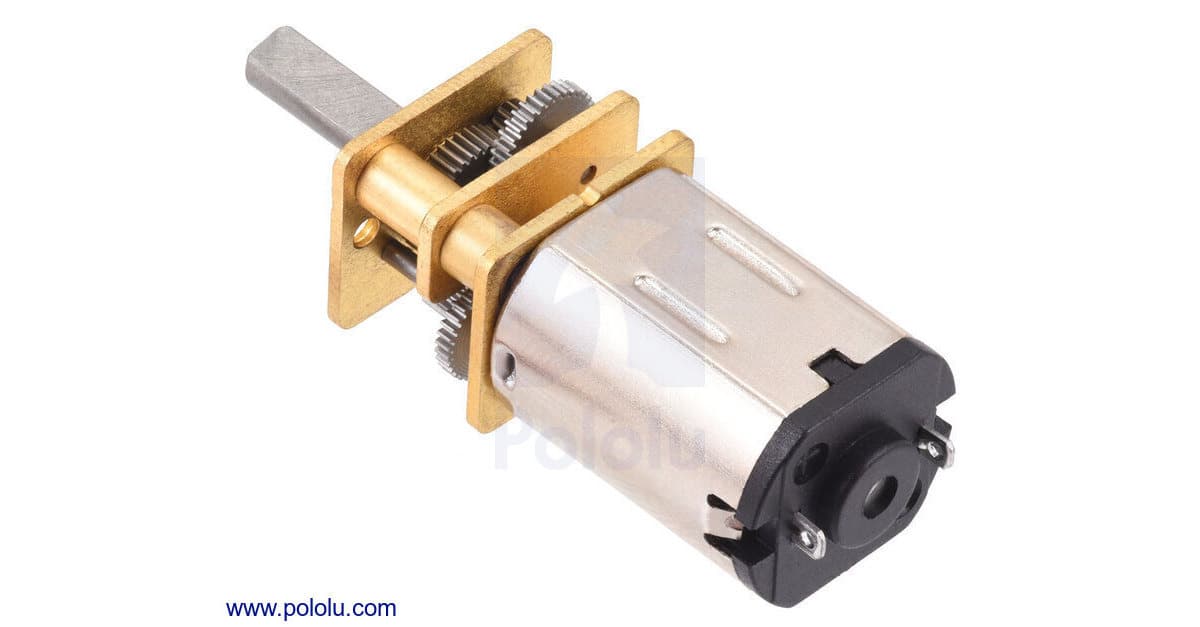
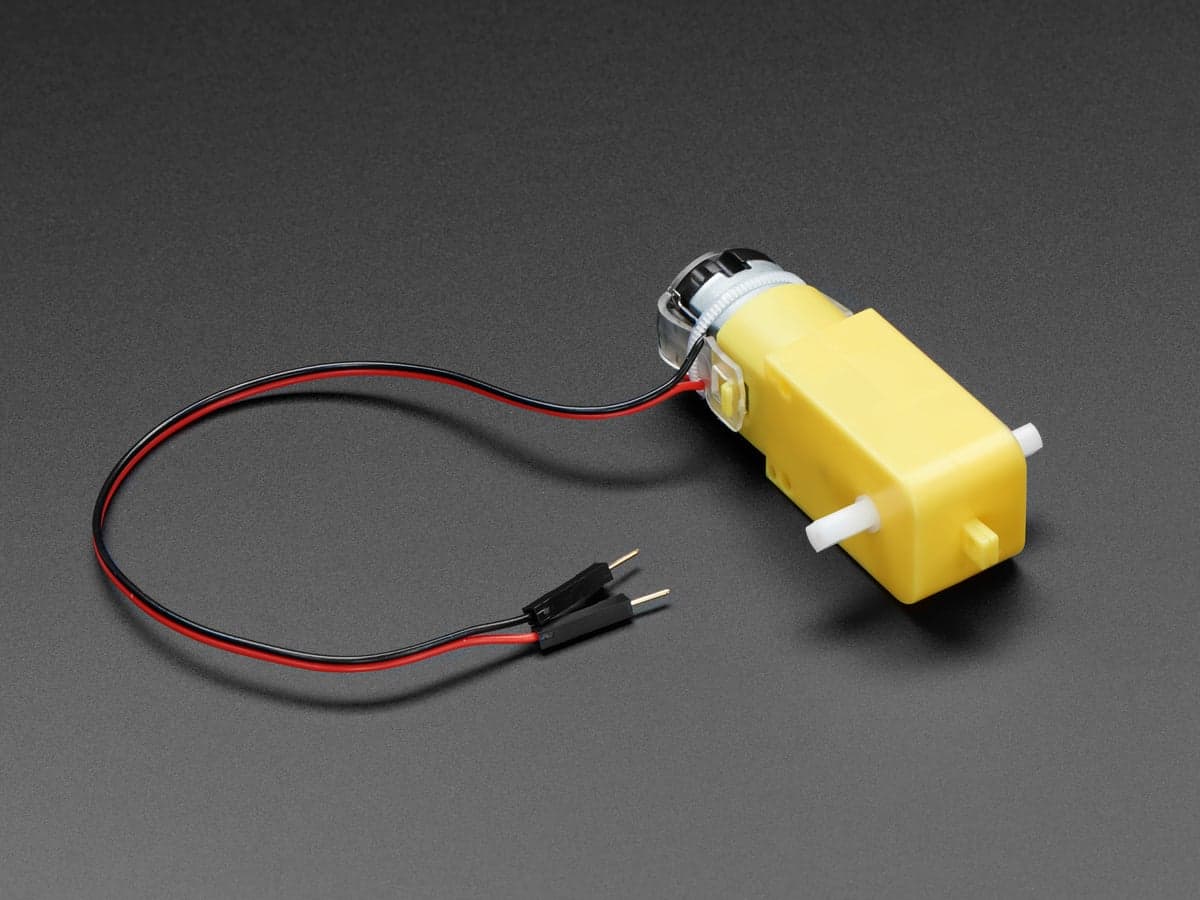 ×2Drive motorsTT DC gearbox motor 200RPM 3-6V
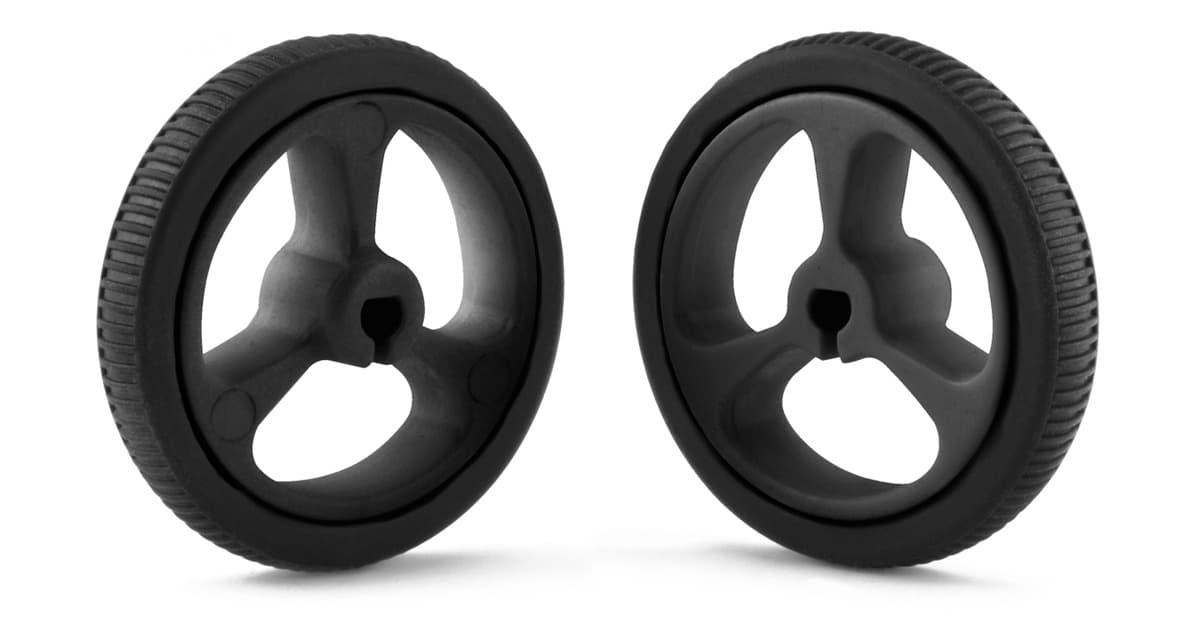
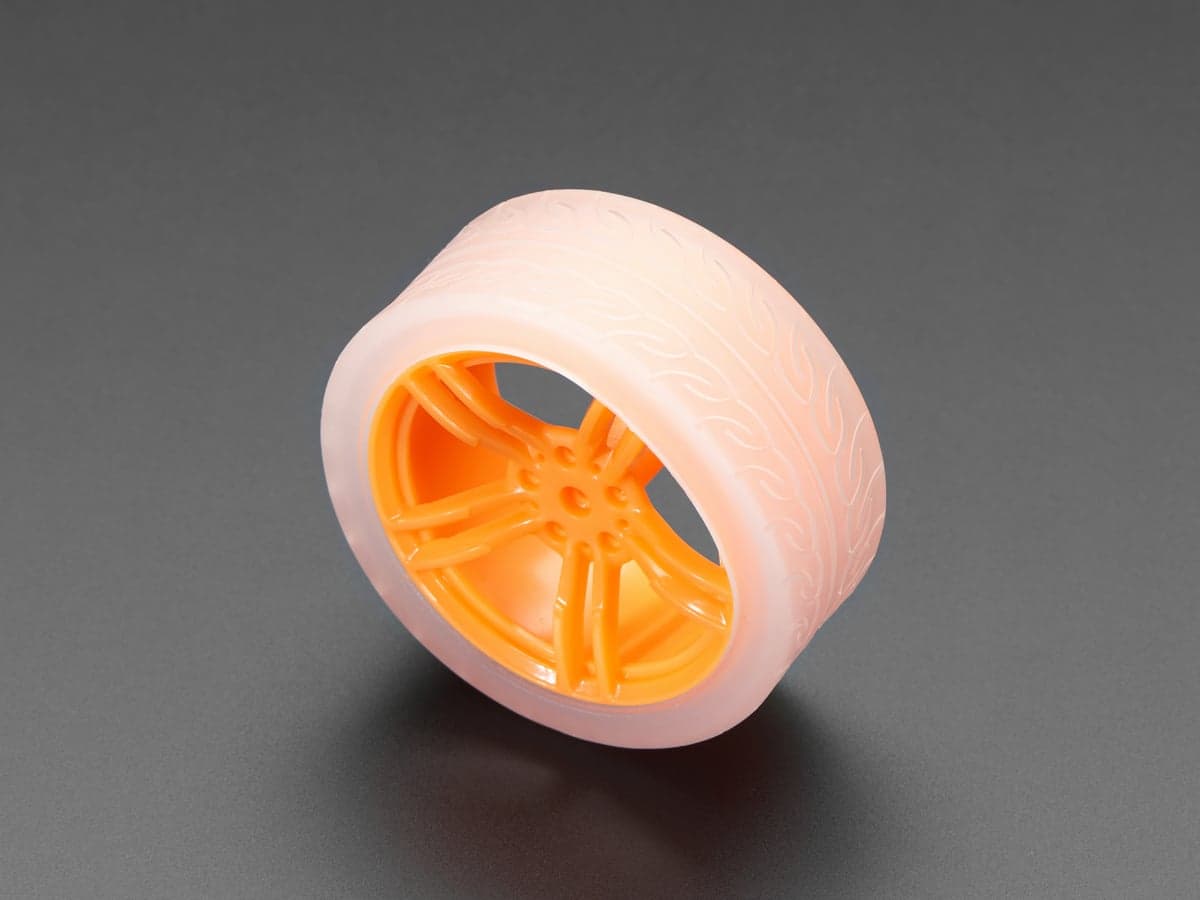 ×2WheelsOrange & clear TT motor wheel
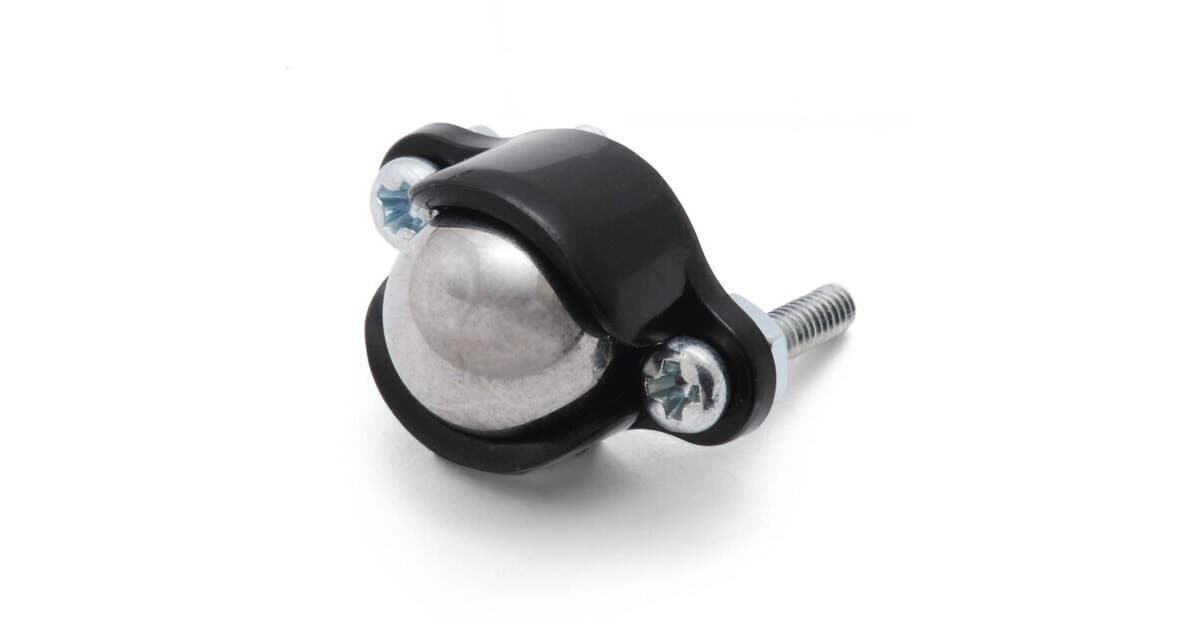 Third contact pointBall caster 3/8 inch metal ball
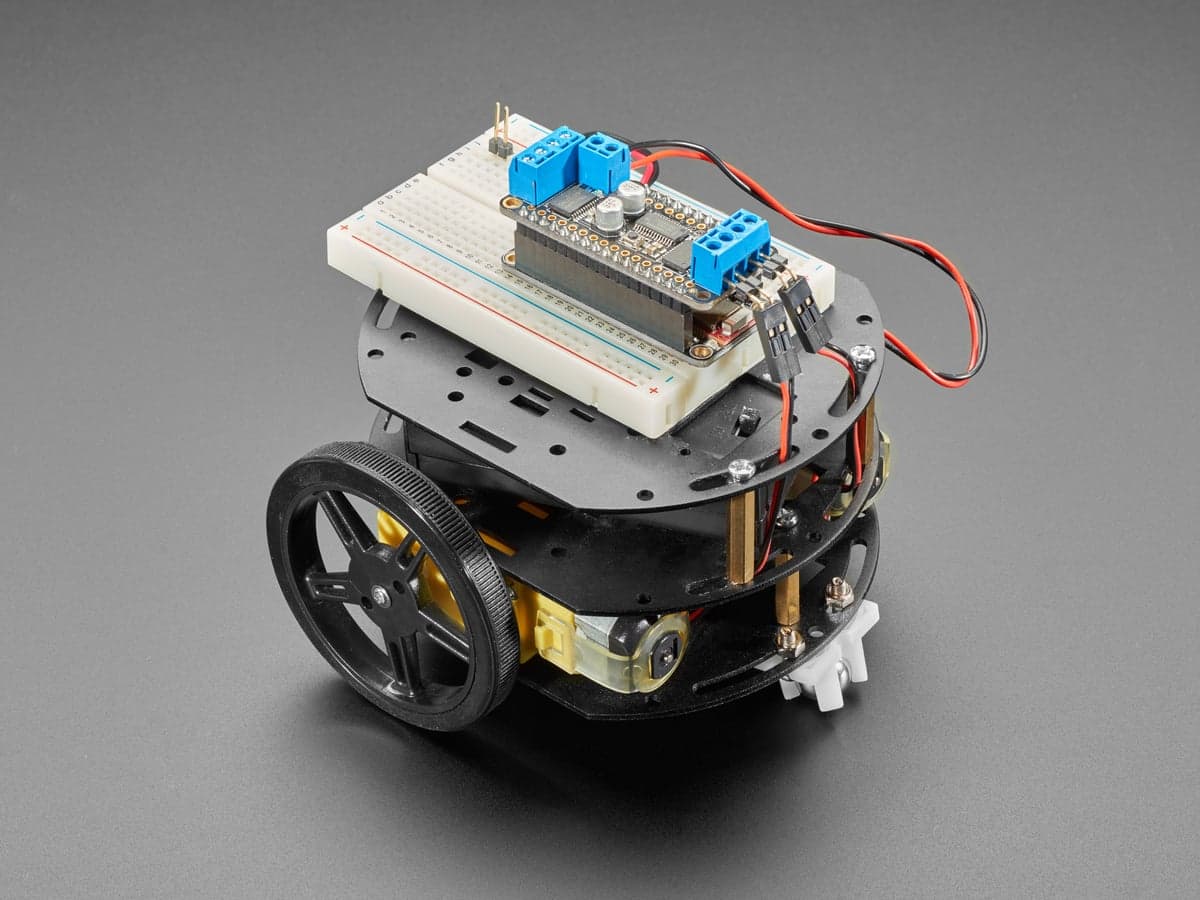 ChassisMini 3-layer round robot chassis kit (2WD)
 Range sensorUltrasonic distance sensor HC-SR04
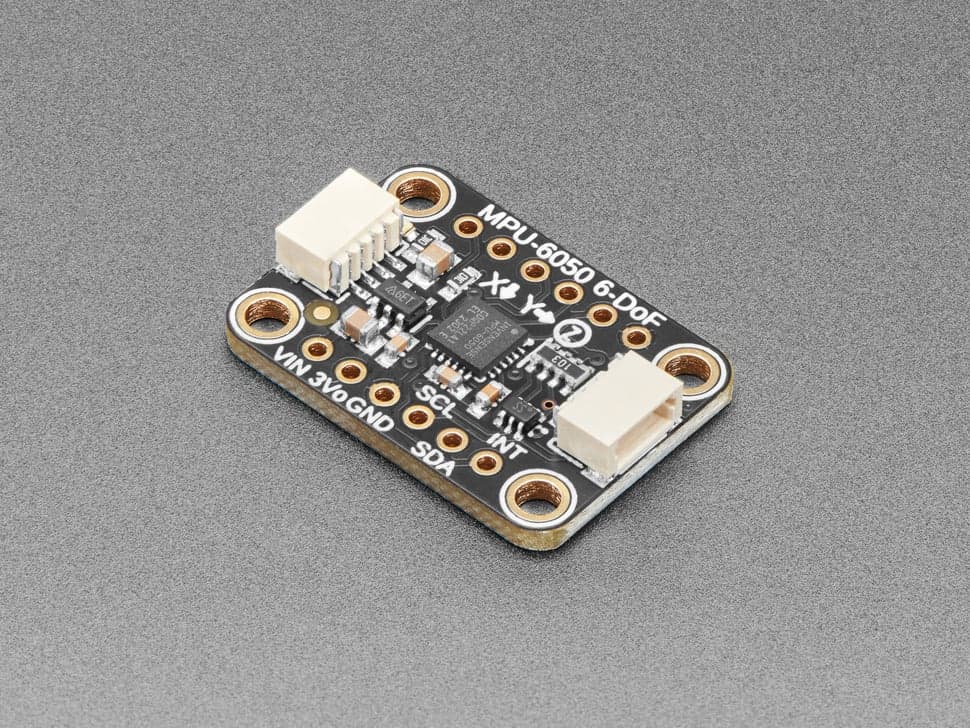 IMUMPU-6050 6-DoF accel + gyro breakout
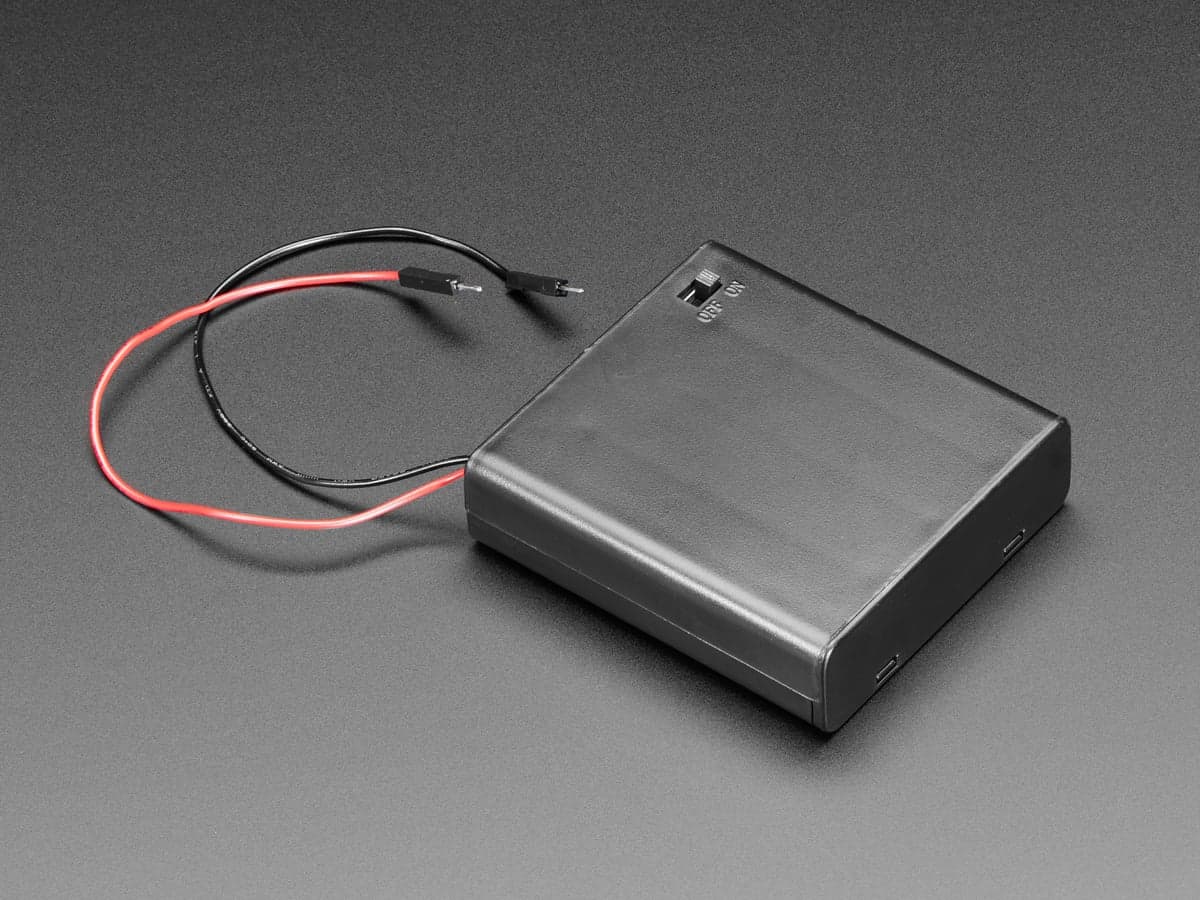 Battery pack4 x AA battery holder with on/off switch
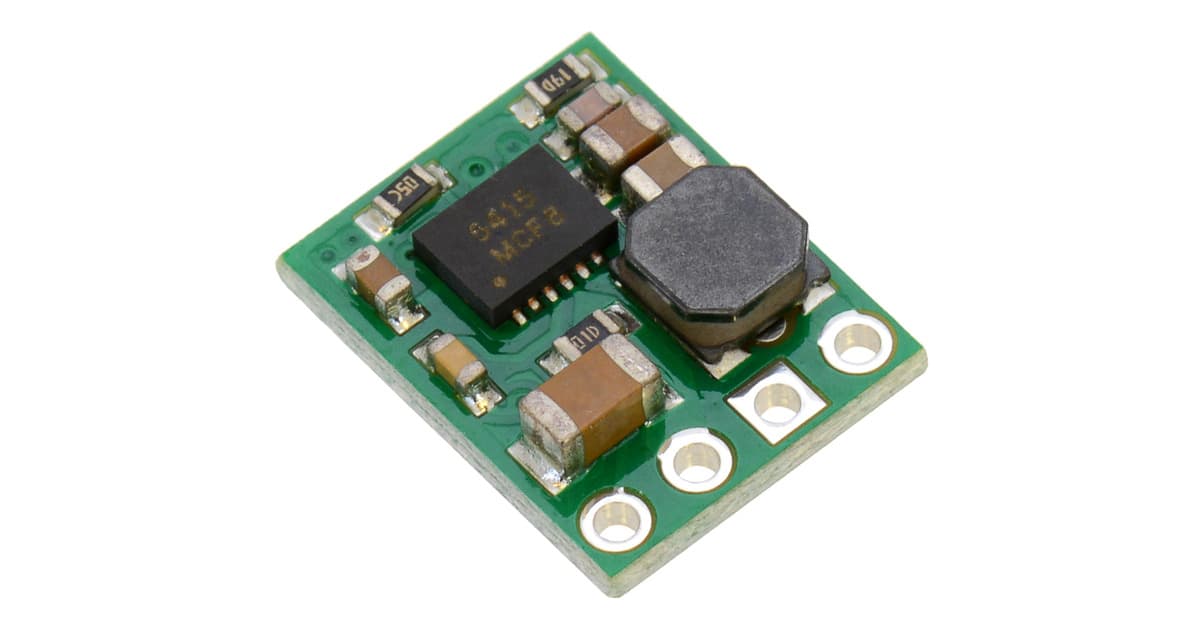 5V rail (optional)5V 500mA step-down regulator D24V5F5
 Power switchBreadboard-friendly SPDT slide switch
 BreadboardHalf-size breadboard
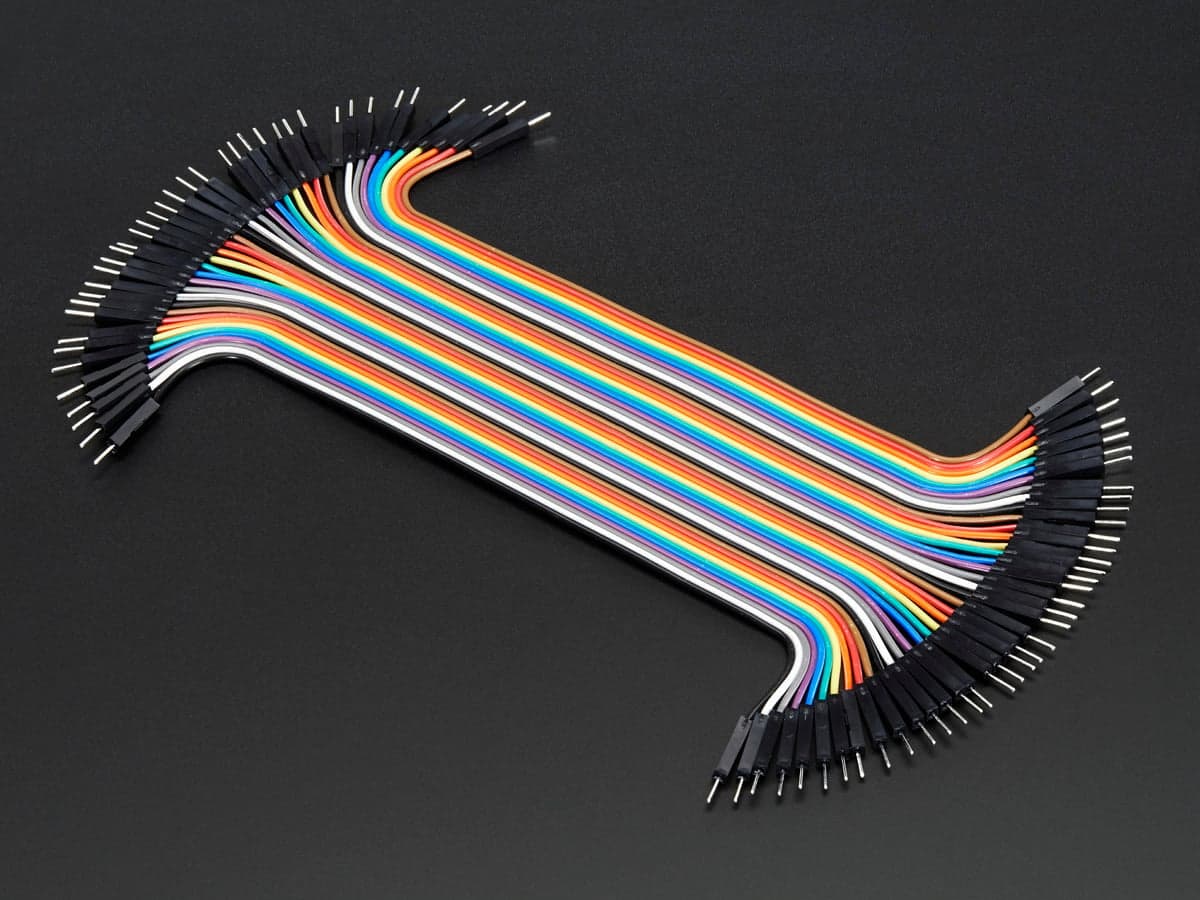 Jumper wiresPremium male/male jumper wires 40 x 150mm
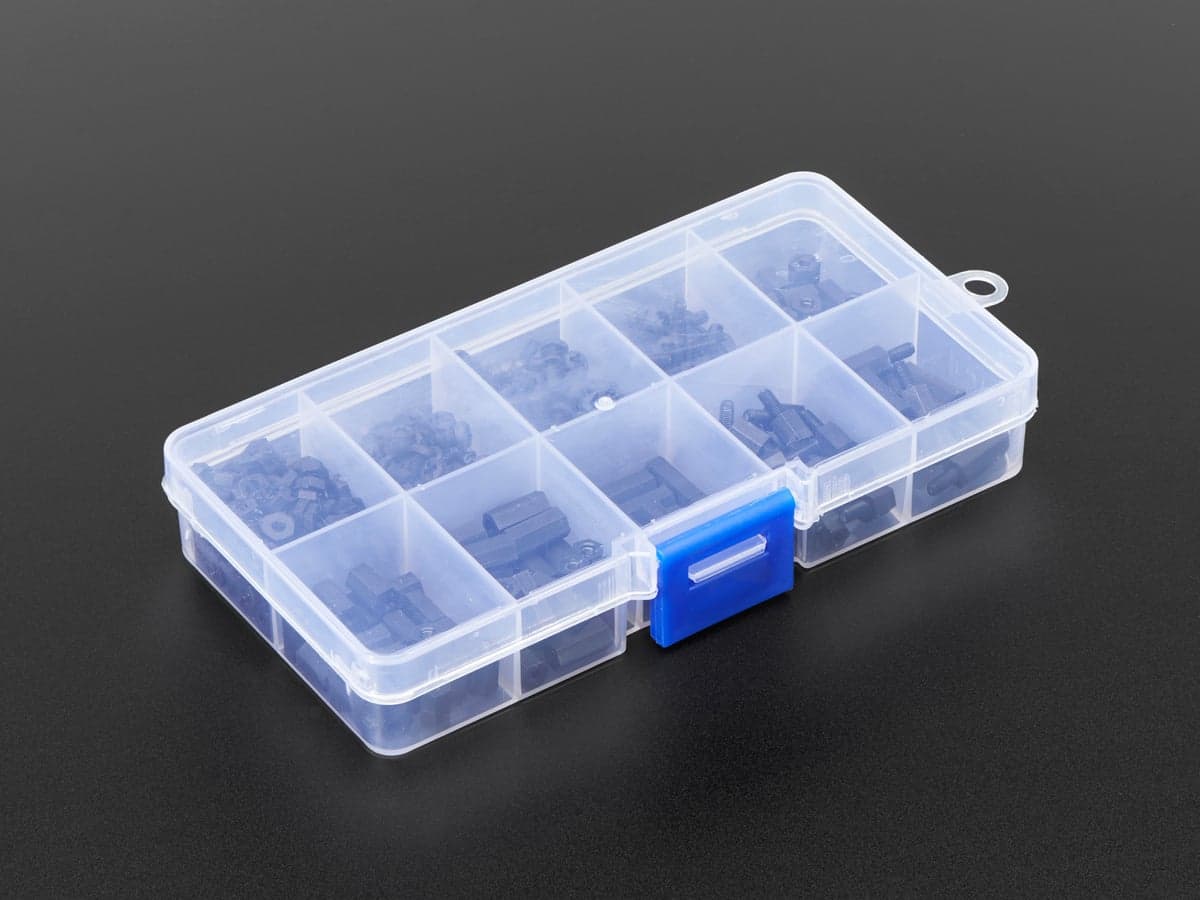 Standoffs and screwsBlack nylon M2.5 screw / standoff kit
角色与候选件
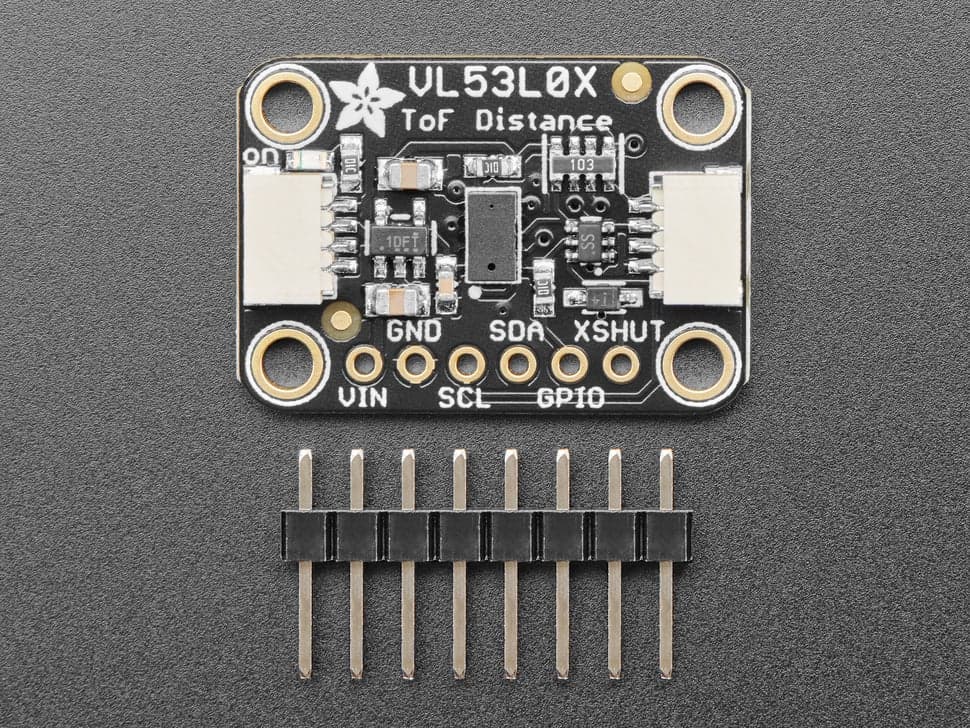
智能体必须满足的约束
- supply-window电机供电必须落在驱动器经佐证的范围内(2.7-10.8 V)。4xAA 电池组在镍氢下为 4.8 V,在碱性下为 6 V — 两者都在范围内。
- controller-supply同一电池组还必须落在控制器的 VSYS 窗口内(经佐证为 1.8-5.5 V)。镍氢的 4.8 V 合适;碱性的 6 V 超出上限 — 请改用镍氢,或加装 5 V 稳压器。
- stall-within-peak电机堵转电流不得超过驱动器每通道的峰值(经佐证为 2 A)。N20 的堵转电流 1.6 A 与 TT 的堵转电流都在其下。
- shaft-match车轮必须与电机轴匹配:32x7 mm 车轮适配 N20 的 3 mm D 形轴;橙色 TT 车轮适配 TT 电机的双 D 形轴。交叉搭配装不上。
- sensor-voltageVL53L0X 模块可接受 3-5 V(经佐证),在 3.3 V 控制器上是稳妥的选择。HC-SR04 需要 5 V — 在 4.8 V 镍氢电池组上很勉强;请优先选 VL53L0X,或加一路 5 V 电源。
- interface控制器必须为驱动器提供 PWM,并为 VL53L0X/MPU-6050 提供 I2C - Pico 2 W 两者都有。